LRT-ECM Series
High load motorized linear stages with brushless DC servo motors, built-in motor encoders, dust covers, and optional brakes
Series Specifications
Download Datasheet| Built-in Controller |  |
| Recommended Controller | MCC (48 V) Recommended |
| AutoDetect |  |
| Travel Range | 100 – 1000 mm |
| Axes of Motion | 1 |
| Weight | 3.726 – 9.095 kg |
| Accuracy (unidirectional) | 45 µm (0.001772") |
| Repeatability | < 4 µm (< 0.000157") |
| Minimum Incremental Move | 6.5 µm |
| Backlash | < 25 µm (< 0.000984") |
| Flatness of Travel | < 10 µm (< 0.000394") |
| Straightness of Travel | < 50 µm (< 0.001968") |
| Pitch Error | 0.015° (0.262 mrad) |
| Roll Error | 0.02° (0.349 mrad) |
| Yaw Error | 0.03° (0.523 mrad) |
| Peak Thrust | 1440 N (322.9 lb) |
| Maximum Axial Brake Force | 1200 N (269.8 lb) |
| Maximum Continuous Thrust | 440 N (98.7 lb) |
| Back-driving Force* | (± 50%) 140 N (31.4 lb) |
| Maximum Centered Load | 2940 N (659.3 lb) |
| Maximum Moment (Pitch) | 70 N⋅m (51.7 lb⋅ft) |
| Maximum Moment (Roll) | 120 N⋅m (88.56 lb⋅ft) |
| Maximum Moment (Yaw) | 70 N⋅m (51.66 lb⋅ft) |
| Stiffness (Pitch) | 1400 N⋅m/° (12 µrad/N⋅m) |
| Stiffness (Roll) | 700 N⋅m/° (25 µrad/N⋅m) |
| Stiffness (Yaw) | 1200 N⋅m/° (15 µrad/N⋅m) |
| Maximum Speed | 240 mm/s (9.449"/s) |
| Minimum Speed | 0.000186 mm/s (0.000007"/s) |
| Speed Resolution | 0.000186 mm/s (0.000007"/s) |
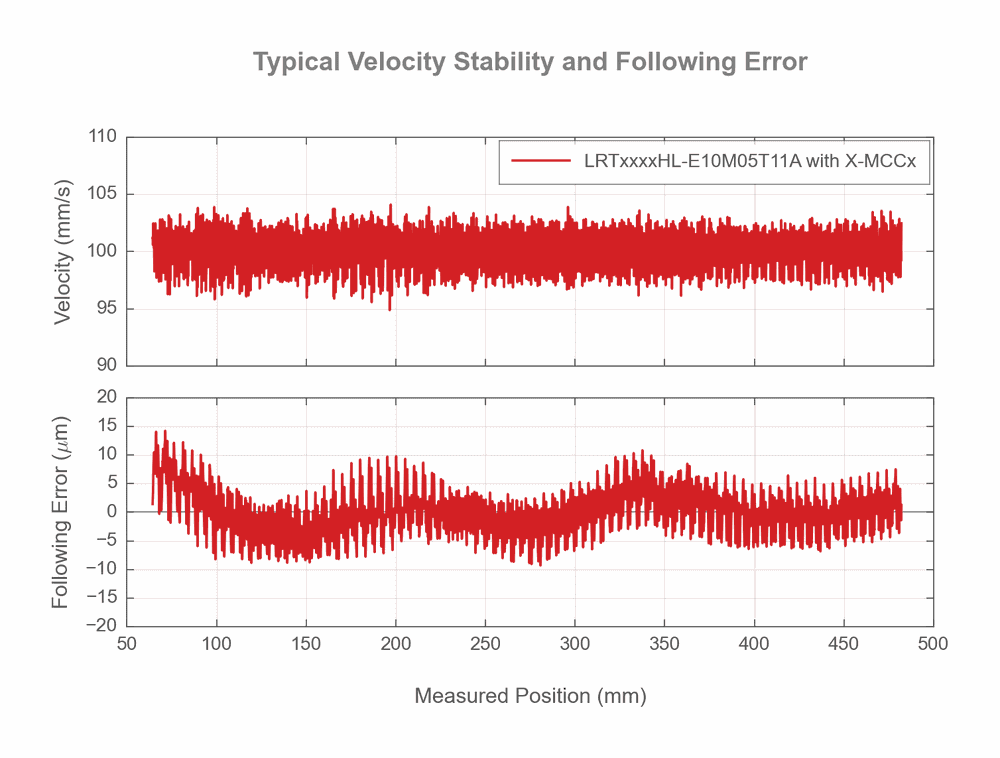
| Typical Velocity Stability | ± 2% at 100 mm/s with a 5 kg payload |
| Encoder Type | Rotary quadrature encoder (single-turn absolute) |
| Encoder Resolution | 4096 CPR (16384 states/rev) |
| Encoder Count Size | 305.176 nm |
| Limit or Home Sensing | Encoder index signal and magnetic home sensor |
| Linear Motion Per Motor Rev | 5 mm (0.197") |
| Motor Type | Brushless DC (3 phase) |
| Motor Rated Current | 5000 mA |
| Motor Winding Resistance | 0.55 ohms line-to-line |
| Motor Winding Inductance | 0.68 mH line-to-line |
| Motor Connection | Varies |
| Guide Type | Recirculating Ball Linear Guide |
| Mechanical Drive System | Precision ball screw |
Filter By Feature
Choose one or more options below to filter the parts table.
LRTTravel: 0100, not selectedLead Screw Options: HDrive Configuration: L-Brake Option: B, not selectedEncoder Options: E10Cover: CMotor Options: M05Connector: T12A, not selected
Showing 10 of 10 parts.Lead Screw Options
Drive Configuration
Brake Option
Encoder Options
Cover
Motor Options
Connector
Part Specifications Comparison
| Part Number | Travel Range | Weight | Maximum Axial Brake Force | Motor Connection |
|---|---|---|---|---|
| LRT0100HL-BE10CM05T12A | 100 mm (3.937") | 4.352 kg (9.595 lb) | 1200 N (269.8 lb) | M12 T-code (motor) and D-sub 26 (sensors) |
| LRT0100HL-E10CM05T11A | 100 mm (3.937") | 3.726 kg (8.214 lb) | — | M12 T-code (motor) and D-sub 15 (sensors) |
| LRT0250HL-BE10CM05T12A | 250 mm (9.843") | 5.143 kg (11.338 lb) | 1200 N (269.8 lb) | M12 T-code (motor) and D-sub 26 (sensors) |
| LRT0250HL-E10CM05T11A | 250 mm (9.843") | 4.517 kg (9.958 lb) | — | M12 T-code (motor) and D-sub 15 (sensors) |
| LRT0500HL-BE10CM05T12A | 500 mm (19.685") | 6.46 kg (14.242 lb) | 1200 N (269.8 lb) | M12 T-code (motor) and D-sub 26 (sensors) |
| LRT0500HL-E10CM05T11A | 500 mm (19.685") | 5.834 kg (12.862 lb) | — | M12 T-code (motor) and D-sub 15 (sensors) |
| LRT0750HL-BE10CM05T12A | 750 mm (29.528") | 7.778 kg (17.148 lb) | 1200 N (269.8 lb) | M12 T-code (motor) and D-sub 26 (sensors) |
| LRT0750HL-E10CM05T11A | 750 mm (29.528") | 7.152 kg (15.767 lb) | — | M12 T-code (motor) and D-sub 15 (sensors) |
| LRT1000HL-BE10CM05T12A | 1000 mm (39.37") | 9.095 kg (20.051 lb) | 1200 N (269.8 lb) | M12 T-code (motor) and D-sub 26 (sensors) |
| LRT1000HL-E10CM05T11A | 1000 mm (39.37") | 8.469 kg (18.671 lb) | — | M12 T-code (motor) and D-sub 15 (sensors) |
Specification Charts & Notes
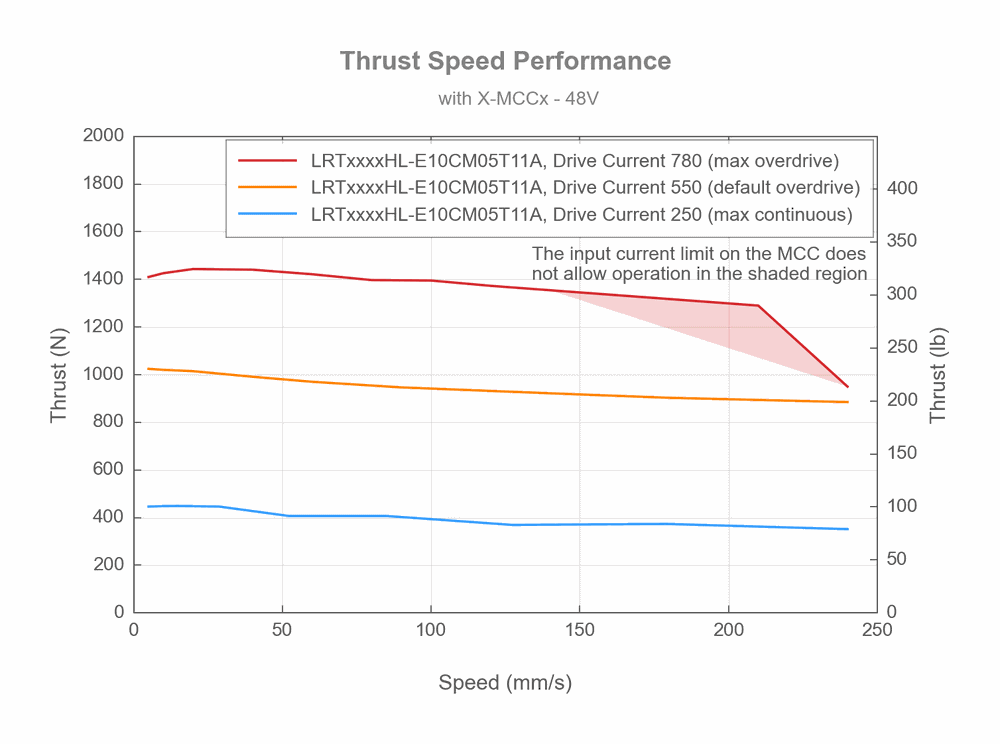
Thrust or torque is a function of speed. The values given above are maximums. These values cannot both be achieved simultaneously (i.e. at maximum speed, the unit will not produce maximum thrust).
Thrust Speed Performance
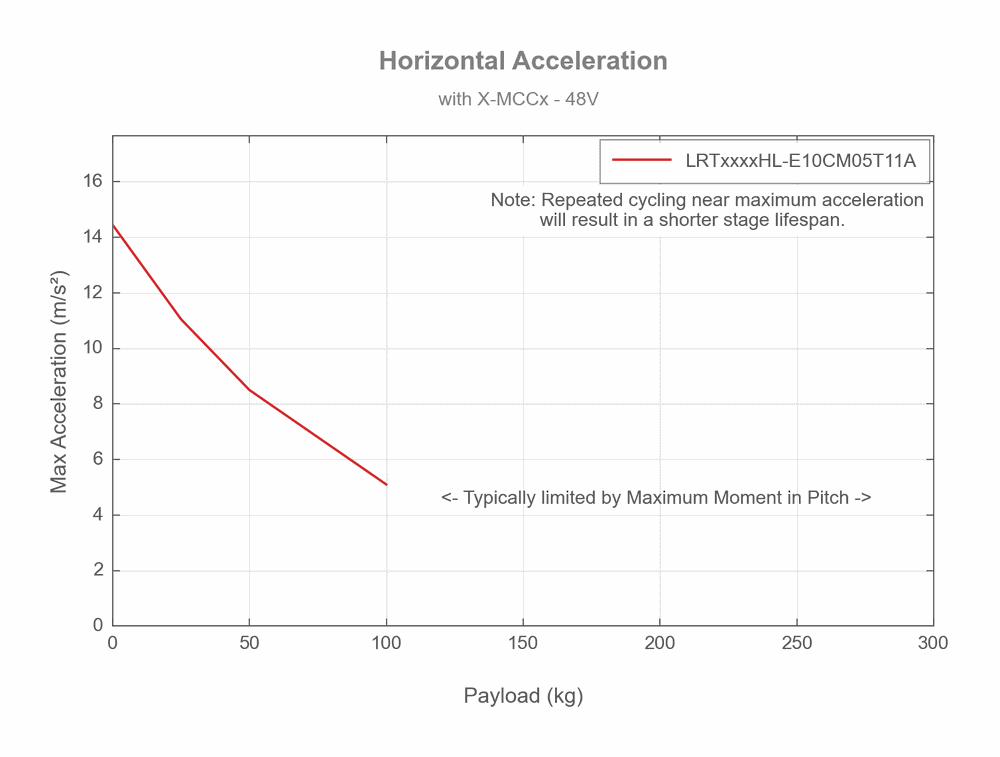
Acceleration
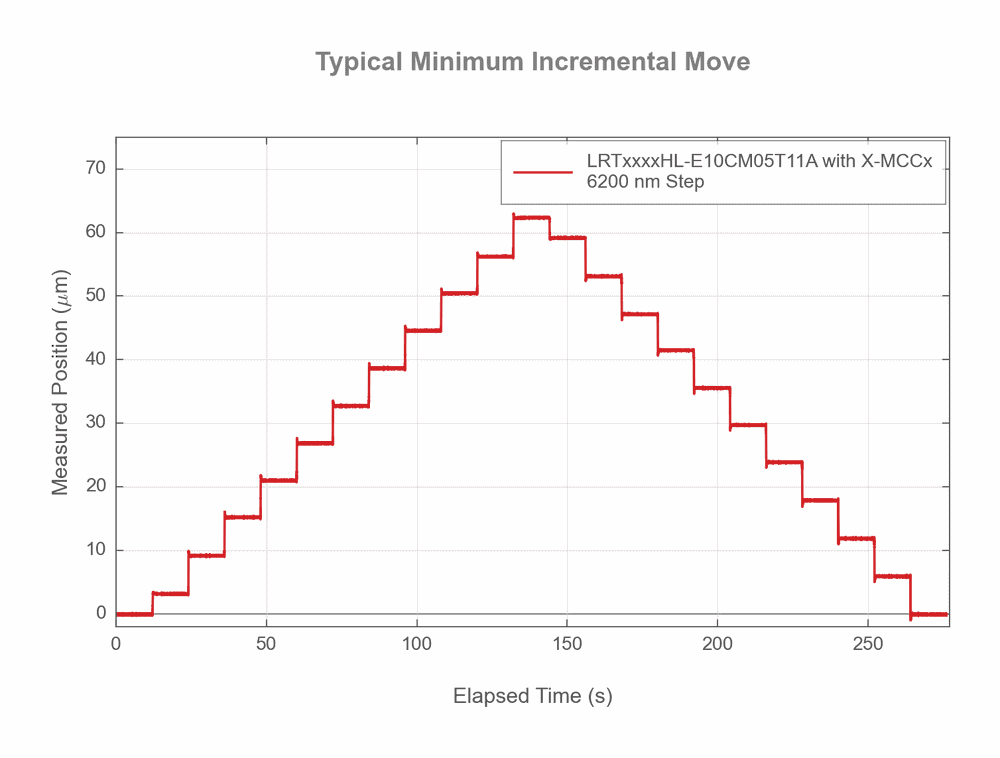
Minimum Incremental Move
Other
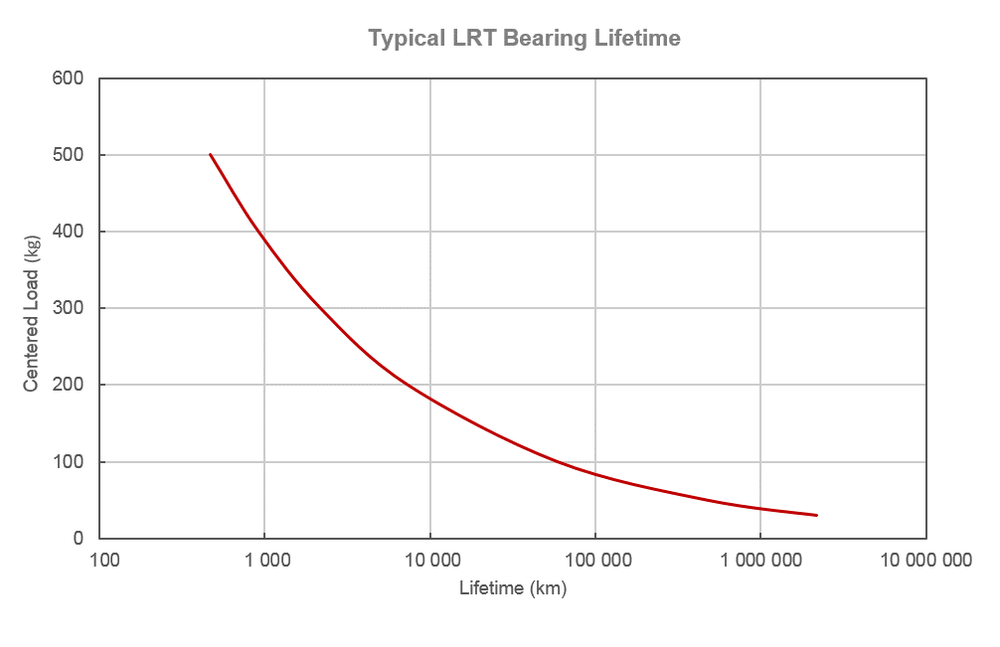
Bearing Lifetime