M-LSM Series
Motorized micromanipulators
Series Specifications
Download Datasheet| Recommended Controller | MCC (48 V) Recommended |
| AutoDetect |  |
| Travel Range | 25.4 mm (1") |
| Axes of Motion | 3 |
| Joystick Control | Velocity Mode |
| Weight | 1.032 kg (2.275 lb) |
| Accuracy (unidirectional) | 15 µm (0.000591") |
| Repeatability | < 3 µm (< 0.000118") |
| Backlash | < 12 µm (< 0.000472") |
| Flatness of Travel | < 8 µm (< 0.000315") |
| Straightness of Travel | < 12 µm (< 0.000472") |
| Pitch Error | 0.02° (0.349 mrad) |
| Roll Error | 0.02° (0.349 mrad) |
| Yaw Error | 0.03° (0.523 mrad) |
| Microstep Size (Default Resolution) | 0.047625 µm |
| Default Resolution | 1/64 of a step |
| Stage Parallelism | < 25 µm (< 0.000984") |
| Peak Thrust | 55 N (12.3 lb) |
| Maximum Speed | 26 mm/s (1.024"/s) |
| Minimum Speed | 0.000029 mm/s (0.000001"/s) |
| Speed Resolution | 0.000029 mm/s (0.000001"/s) |
| Encoder Type |  |
| Limit or Home Sensing | Magnetic hall sensor |
| Linear Motion Per Motor Rev | 0.6096 mm (0.024") |
| Motor Steps Per Rev | 200 |
| Motor Type | Stepper (2 phase) |
| Motor Rated Current | 600 mA/phase |
| Motor Winding Resistance | 6.5 ohms/phase |
| Motor Winding Inductance | 3.5 mH/phase |
| Motor Rated Power | 6.9 watts |
| Motor Connection | D-sub 15 |
| Communication Interface | RS-232, USB 2.0 |
| Communication Protocol | Zaber ASCII (Default), Zaber Binary |
| Probe Diameter Range | 2-13 mm (0.079") |
| Probe Angle Range | 360° (6.283 rad) |
| Guide Type | Recirculating ball bearing |
| Mechanical Drive System | Precision lead screw |
Filter By Feature
Choose one or more options below to filter the parts table.
M-LSMTravel: 025Lead Screw Options: ATravel: 025Lead Screw Options: ATravel: 025Lead Screw Options: AHanded: LH, not selectedZ-Mounting Options: F, not selected-Connector: T4A
Showing 4 of 4 parts.Lead Screw Options
Travel
Lead Screw Options
Travel
Lead Screw Options
Handed
Z-Mounting Options
Connector
Specification Charts & Notes
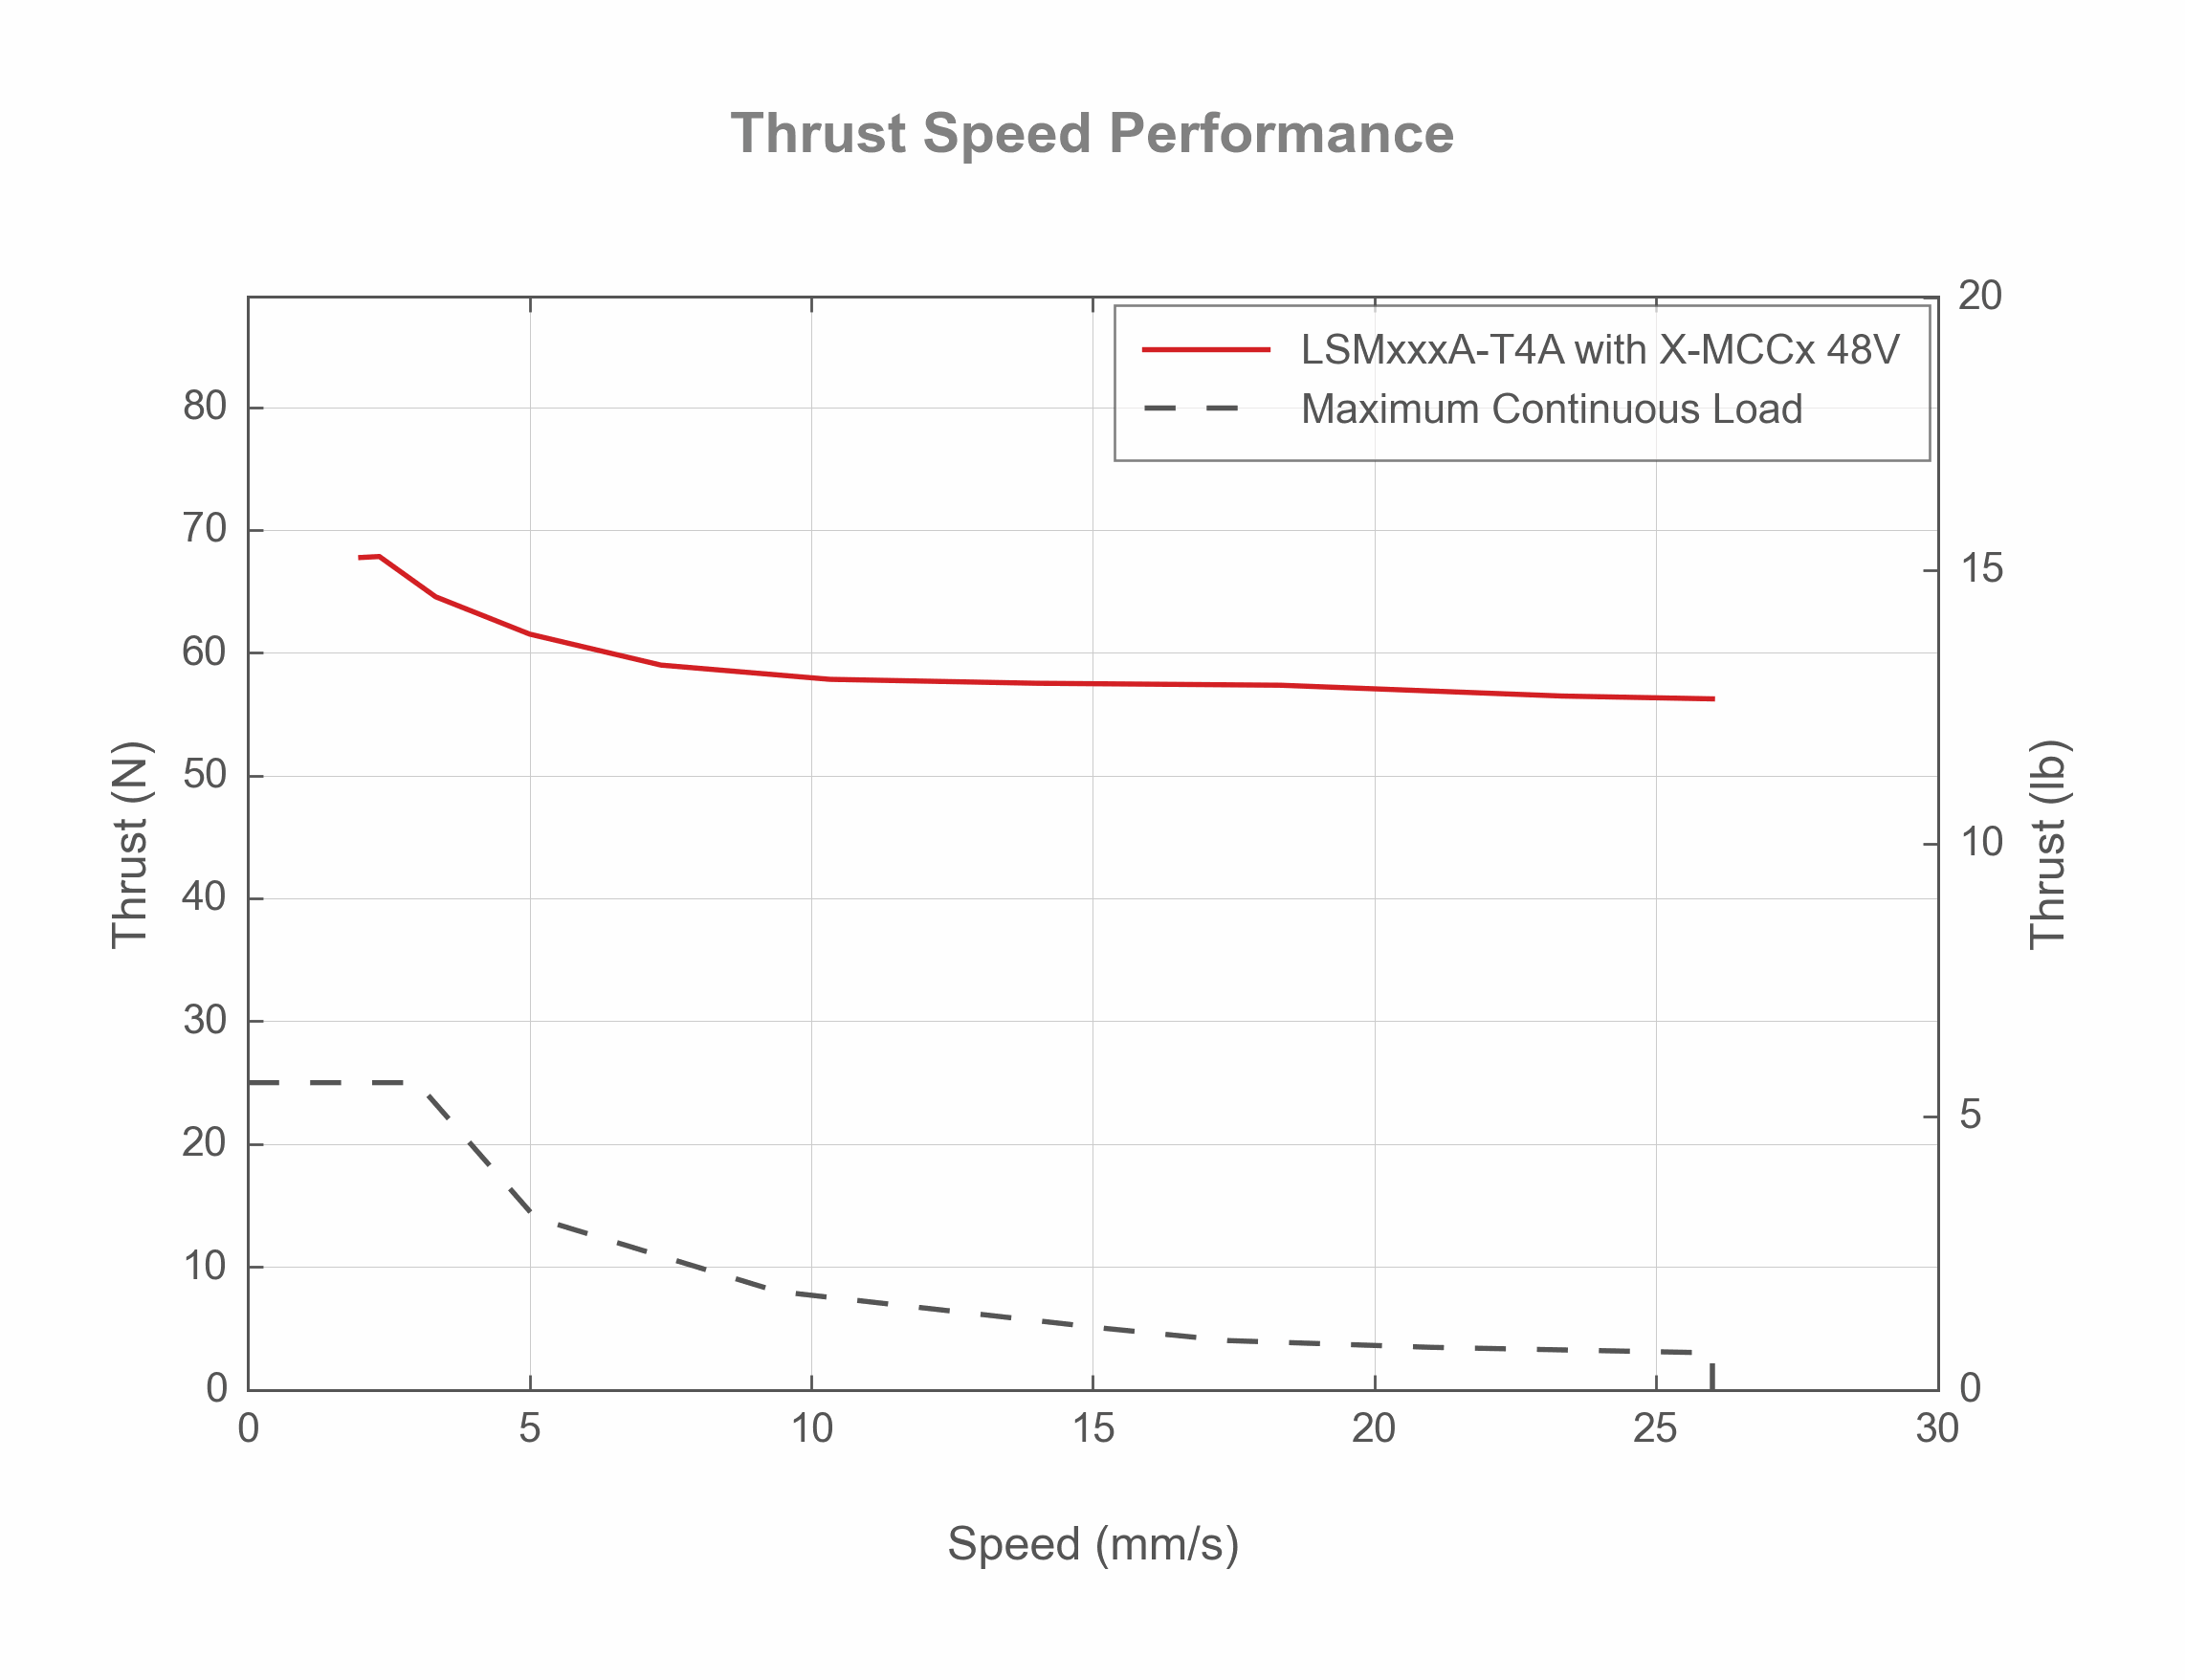
Thrust or torque is a function of speed. The values given above are maximums. These values cannot both be achieved simultaneously (i.e. at maximum speed, the unit will not produce maximum thrust).
Thrust Speed Performance
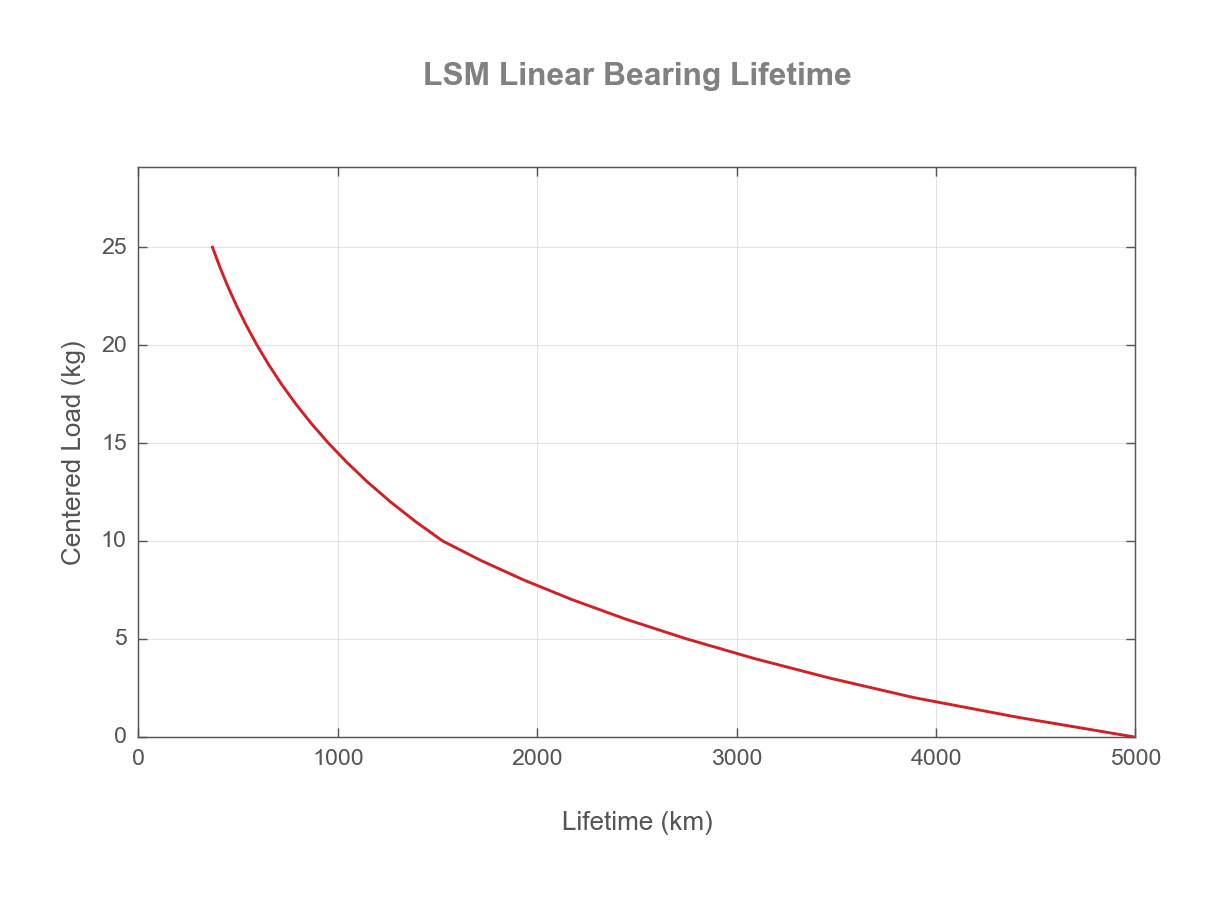
Bearing Lifetime